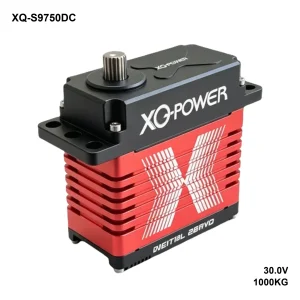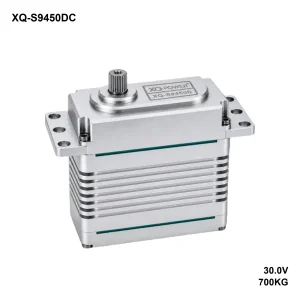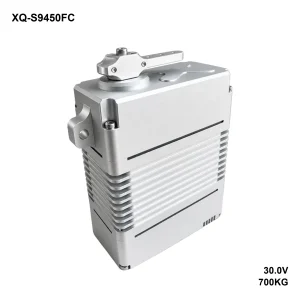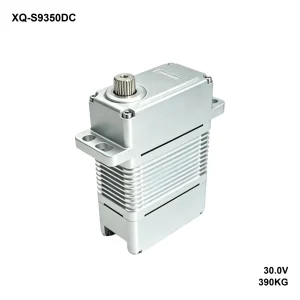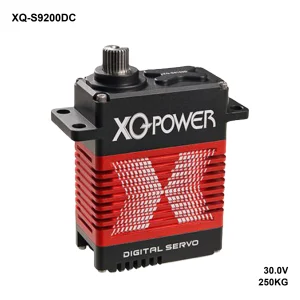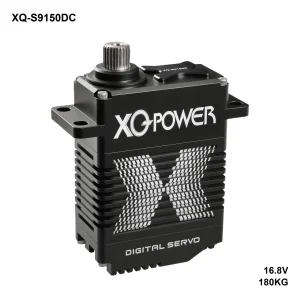
CAN Bus Servo Motors
CAN bus servos share one differential pair across a whole machine, which is what makes them the usual choice for robot joints, AGV steering and multi-axis gantries where a star of PWM cables would not route.
Every model here is built on the same mechanical platform as its PWM and RS-485 siblings: identical case, geartrain and output spline. Only the control board and connector differ, so a machine can be prototyped on PWM and moved to CAN without redesigning the linkage.
The inspection sheet lists CAN as the command signal; the message map, bit rate and node ID range are supplied separately. Terminate the bus at both ends and keep the power pair away from the signal pair.
Showing 1–12 of 14 results