| 100KG·CM STALL | 0.160S/60° NO-LOAD | 30V RATED |
| 290G WEIGHT | SteelGEARTRAIN | 360°TRAVELCustomizable |
Overview
The XQ-S9080FC is the CAN bus build of the 30 V 100 kg·cm servo, for machines where CAN is already the backbone — mobile robots, AGVs, agricultural implements, anything with a vehicle bus and a handful of actuators to drive.
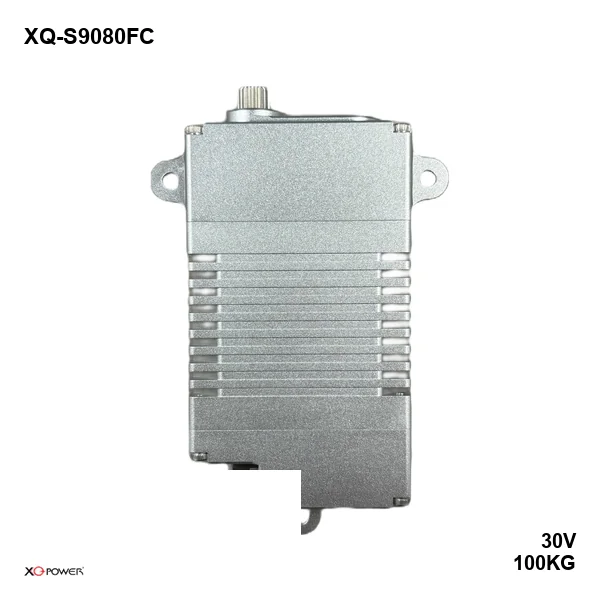
Mechanically it is identical to the other two 9080 variants: 54 × 25 × 96 mm of milled 6051 aluminium, 290 g, six ball bearings, steel geartrain, 25T-φ7.96 output spline with a 7075 aluminium horn, J30J-9TJL connector. Ratings are 75, 90 and 100 kg·cm at 24, 28 and 30 V.
CAN gives arbitration and error checking in hardware, so a dropped frame does not become a servo moving to a wrong angle. That is the reason to choose it over RS-485 when several nodes share the bus and one of them is safety-relevant.
Performance at each supply voltage
| Supply | No-load speed | Peak stall torque | Idle current | Stall current |
|---|---|---|---|---|
| 24 V | 0.280 s/60° (214 °/s) | 75 kg·cm (7.36 N·m / 1042 oz·in) | 150 mA | <2 A |
| 28 V | 0.200 s/60° (300 °/s) | 90 kg·cm (8.83 N·m / 1250 oz·in) | 180 mA | <2.5 A |
| 30 V | 0.160 s/60° (375 °/s) | 100 kg·cm (9.81 N·m / 1389 oz·in) | 200 mA | <3 A |
Control specification
| Item | Specification |
|---|---|
| Command signal | CAN bus |
| Amplifier | Digital controller |
| Dead band | 3 µs |
| Rotating direction | CCW (1000–2000 µs), customizable |
| Travel | 360°, customizable |
Mechanical specification
| Item | Specification | Item | Specification |
|---|---|---|---|
| Dimensions | 54 × 25 × 96 mm | Case material | Aluminium 6051, CNC |
| Weight | 290 g | Geartrain | Steel |
| Bearings | 6 × ball bearing | Motor | Brushless |
| Output spline | 25T-φ7.96 mm | Horn | 7075 aluminium, CNC |
| Lead / connector | J30J-9TJL connector, sold separately | Mechanical limit | — |
| Operating temperature | −30 °C to 65 °C | Storage temperature | −30 °C to 70 °C |
| Ingress protection | Splash resistant (customizable) | Travel | 360°, customizable |
What’s in the box
- 1 × XQ-S9080FC servo
- 1 × 7075 aluminium horn
- 1 × mounting screw pack
The J30J-9TJL mating cable is not included; it is ordered separately to suit your harness.
How to size it
As with every bus build, power is separate from data. Plan a 24–30 V distribution that can carry 3 A per node at stall, and terminate the CAN bus at both physical ends — an unterminated 5 m run is the usual cause of nodes dropping off under load.
Torque depends on the rail, not the bus: 75 kg·cm at 24 V, 90 at 28 V, 100 at 30 V. If the vehicle bus sits at 24 V nominal and dips to 22 V under cranking, size the linkage at the dipped number.
FAQ
Which bus should I choose for a mobile robot?
CAN, if the robot already has a CAN backbone. It handles multi-node arbitration and error detection in hardware, and the same wiring can carry the rest of the machine’s devices.
What bitrate and message set does it use?
Not printed on the inspection sheet. Ask for the CAN message set, bitrate options and node ID range before integration.
Is 360° travel available?
Yes. The running degree is 360° and customizable, set at build time rather than by firmware. State the travel with the quote.
Is the harness included?
No — the servo terminates in a J30J-9TJL connector and the mating cable is ordered separately.
Other interfaces
Downloads
- XQ-S9080FC inspection specification (PDF, 1911 KB)
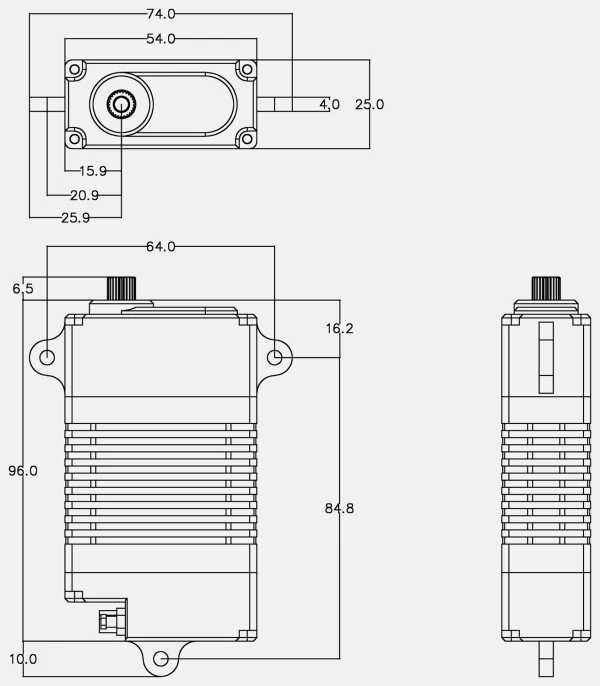
Torque, speed and current at each supply voltage, mechanical data, control specification, mounting dimensions. - 2D dimension drawing (image)
Mounting hole positions, case depth and overall height; the same drawing is inside the datasheet.