| 100KG·CM STALL | 0.160S/60° NO-LOAD | 30V RATED |
| 290G WEIGHT | SteelGEARTRAIN | 360°TRAVELCustomizable |
Overview
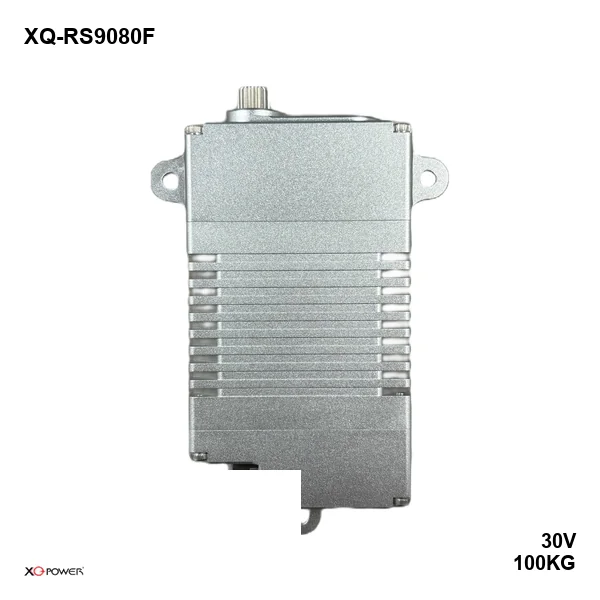
The XQ-RS9080F is the RS-485 build of the 30 V 100 kg·cm servo. Same milled 6051 aluminium case, same 290 g, same six bearings and steel geartrain — the difference is that it is addressed over a differential serial bus instead of a PWM channel.
RS-485 is the right choice when the servos are far from the controller. A differential pair survives long cable runs and electrically noisy cabinets in a way that a single-ended PWM line does not, and a multi-drop bus means one cable can serve a whole row of actuators.
Electrical numbers are unchanged: 75, 90 and 100 kg·cm at 24, 28 and 30 V, 0.28 to 0.16 s/60°, stall current under 3 A. The output is a 25T-φ7.96 spline on a 7075 aluminium horn, with a J30J-9TJL connector for the user-supplied harness.
Performance at each supply voltage
| Supply | No-load speed | Peak stall torque | Idle current | Stall current |
|---|---|---|---|---|
| 24 V | 0.280 s/60° (214 °/s) | 75 kg·cm (7.36 N·m / 1042 oz·in) | 150 mA | <2 A |
| 28 V | 0.200 s/60° (300 °/s) | 90 kg·cm (8.83 N·m / 1250 oz·in) | 180 mA | <2.5 A |
| 30 V | 0.160 s/60° (375 °/s) | 100 kg·cm (9.81 N·m / 1389 oz·in) | 200 mA | <3 A |
Control specification
| Item | Specification |
|---|---|
| Command signal | RS-485 (Modbus) |
| Amplifier | Digital controller |
| Dead band | 3 µs |
| Rotating direction | CCW (1000–2000 µs), customizable |
| Travel | 360°, customizable |
Mechanical specification
| Item | Specification | Item | Specification |
|---|---|---|---|
| Dimensions | 54 × 25 × 96 mm | Case material | Aluminium 6051, CNC |
| Weight | 290 g | Geartrain | Steel |
| Bearings | 6 × ball bearing | Motor | Brushless |
| Output spline | 25T-φ7.96 mm | Horn | 7075 aluminium, CNC |
| Lead / connector | J30J-9TJL connector, sold separately | Mechanical limit | — |
| Operating temperature | −30 °C to 65 °C | Storage temperature | −30 °C to 70 °C |
| Ingress protection | Splash resistant (customizable) | Travel | 360°, customizable |
What’s in the box
- 1 × XQ-RS9080F servo
- 1 × 7075 aluminium horn
- 1 × mounting screw pack
The J30J-9TJL mating cable is not included; it is ordered separately to suit your harness.
How to size it
Power is still point-to-point. The bus carries commands, not torque — run a separate 24–30 V pair to every node or to a local distribution block, and tie the bus ground to the power ground once, at the controller.
Stall current under 3 A per node keeps a multi-axis run manageable: eight of these on one 30 V supply is under 24 A at simultaneous stall, which is a realistic size for an industrial PSU rather than a battery.
FAQ
Which one should I pick, PWM, RS-485 or CAN?
PWM if the servo sits next to its controller and you already have PWM outputs. RS-485 if the runs are long or noise is the problem. CAN if the rest of the machine already speaks CAN.
Do you publish the register map?
The inspection sheet covers mechanics and electrical ratings, not the protocol. Ask for the register map, baud rate options and node ID range before integration — they are supplied with the unit on request.
Is the 360° travel a firmware setting?
No firmware setting is involved — the running degree is 360° and customizable, set when the servo is built. State the travel you need with the quote.
Is the cable included?
No. The servo ends in a J30J-9TJL connector; the mating cable is a separate item.
Other interfaces
Downloads
- XQ-RS9080F inspection specification (PDF, 1904 KB)
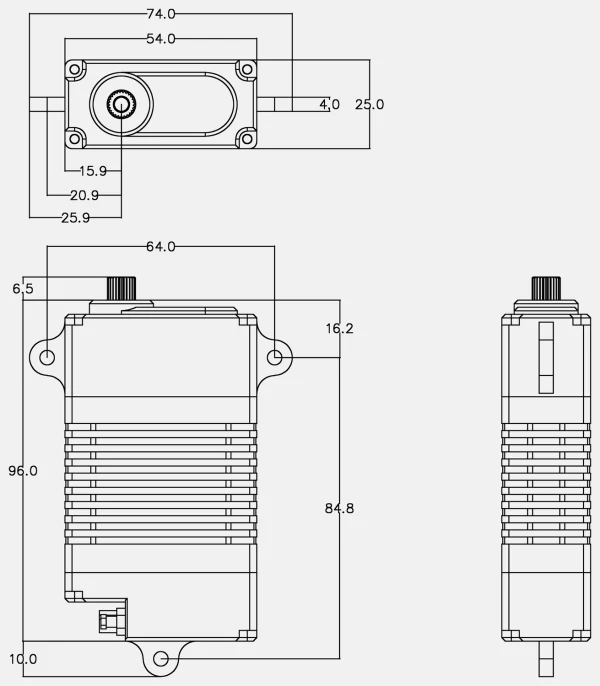
Torque, speed and current at each supply voltage, mechanical data, control specification, mounting dimensions. - 2D dimension drawing (image)
Mounting hole positions, case depth and overall height; the same drawing is inside the datasheet.