| 40KG·CM STALL | 0.070S/60° NO-LOAD | 12V RATED |
| 78G WEIGHT | StainlessGEARTRAIN | 360°TRAVELCustomizable |
Overview
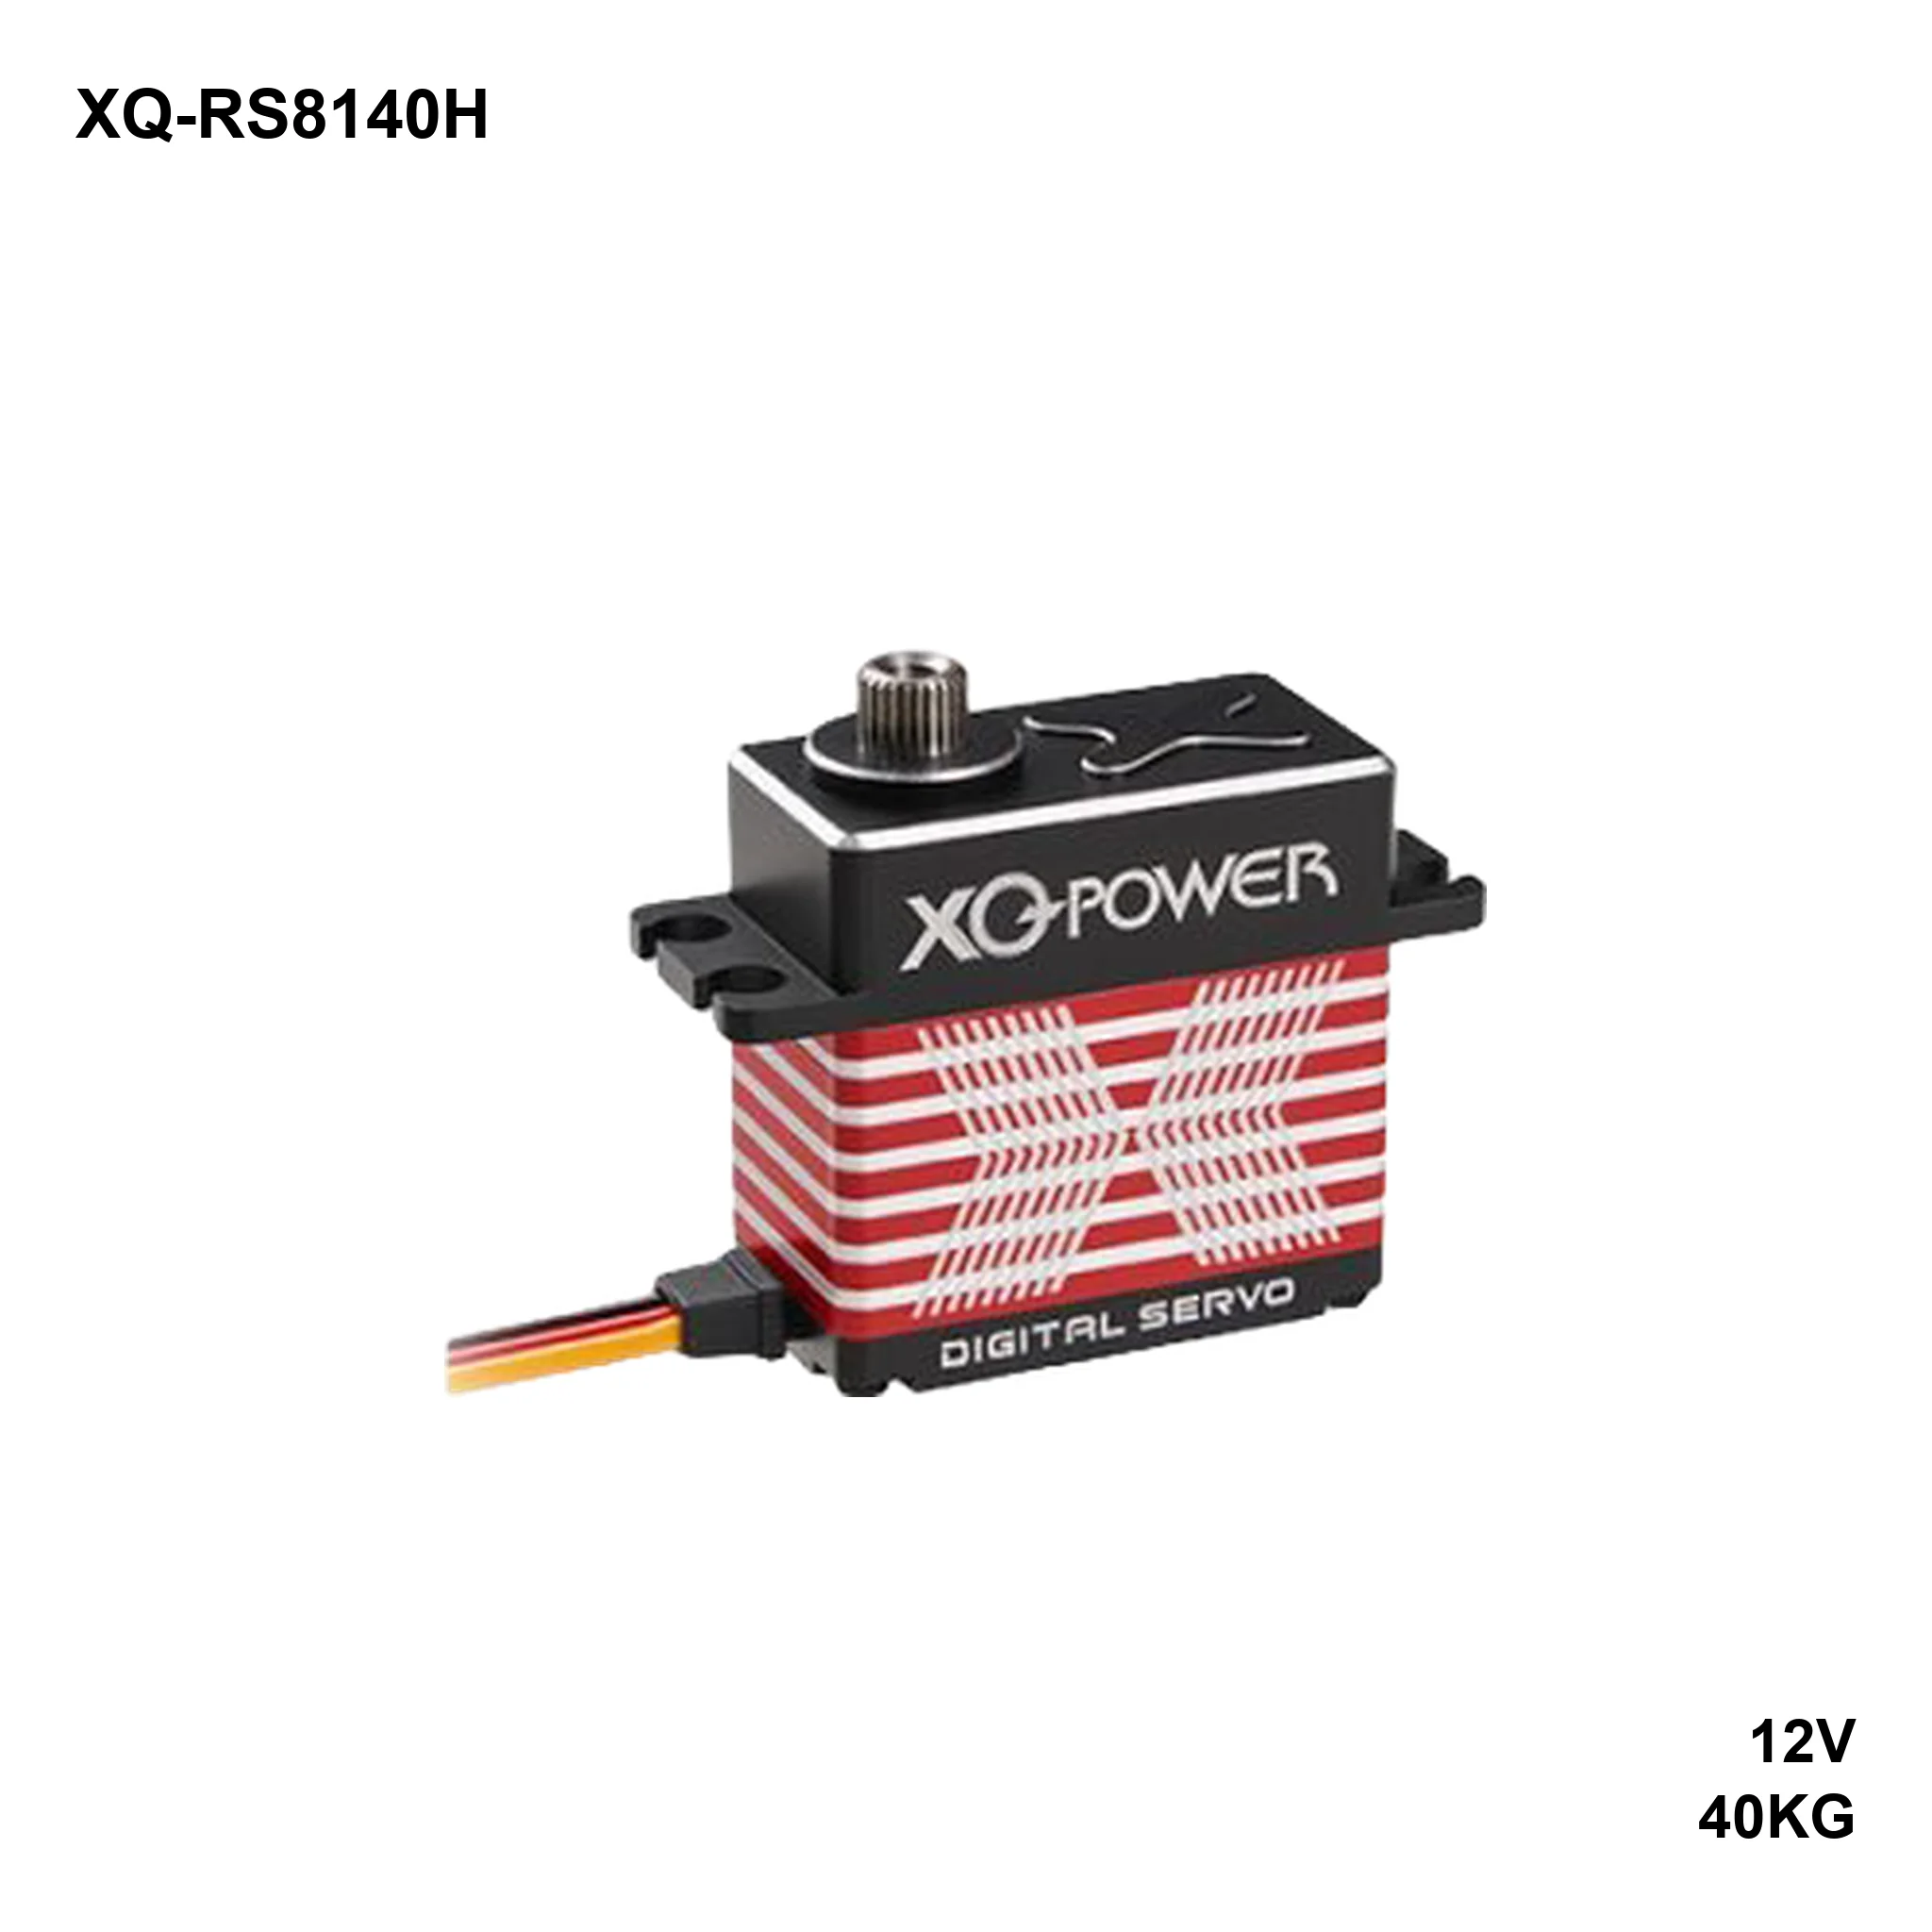
The BLS8140H is the 12 V build of the standard-size brushless servo: 40 kg·cm at 0.07 s/60° on a 3S rail, 78 g in a 20 × 40 × 38 mm aluminium case. On 8.4 V it is a 29 kg·cm servo and on 7.4 V a 25 kg·cm one, so it stays usable across a 2S to 3S swap.
The inspection sheet names it a tail servo and it carries the 8H series code, but the control window is the standard 800–2200 µs with a **1520 µs** neutral — 20 µs off the usual 1500. That offset is small enough to be invisible on a stick and large enough to matter on a gyro that expects a true centre, so trim it out on the bench before the first flight.
This page covers the RS-485 build: the same mechanics, commanded over a differential serial bus instead of a PWM channel. It is the version to pick when several servos sit on one pair of wires or when the cable run is long enough that a single-ended signal would pick up noise.
Performance at each supply voltage
| Supply | No-load speed | Peak stall torque | Idle current | Stall current |
|---|---|---|---|---|
| 7.4 V | 0.110 s/60° (545 °/s) | 25 kg·cm (2.45 N·m / 347 oz·in) | 320 mA | 2.8 A |
| 8.4 V | 0.094 s/60° (638 °/s) | 29 kg·cm (2.84 N·m / 403 oz·in) | 370 mA | 3.5 A |
| 12 V | 0.070 s/60° (857 °/s) | 40 kg·cm (3.92 N·m / 555 oz·in) | 440 mA | 4.0 A |
Control specification
| Item | Specification |
|---|---|
| Command signal | RS-485 |
| Amplifier | Digital controller |
| Dead band | 1 µs |
| Rotating direction | CCW (1000–2000 µs) |
| Travel | 360°, customizable |
Mechanical specification
| Item | Specification | Item | Specification |
|---|---|---|---|
| Dimensions | 20 × 40 × 38 mm | Case material | Aluminium, CNC |
| Weight | 78 g | Geartrain | Stainless steel |
| Bearings | 2 × ball bearing | Motor | Brushless |
| Output spline | 25T-φ5.96 mm | Horn | Plastic, POM |
| Lead / connector | 300 mm, 22 AWG | Mechanical limit | 210° |
| Operating temperature | −15 °C to 65 °C | Storage temperature | −20 °C to 70 °C |
| Ingress protection | Splash resistant (customizable) | Travel | 360°, customizable |
What’s in the box
- 1 × XQ-RS8140H servo
- 1 × POM horn set
- 1 × mounting screw pack
Optional: metal horn, sold separately.
How to size it
Torque is 25 kg·cm at 7.4 V, 29 at 8.4 V and 40 at 12 V, at 0.11, 0.094 and 0.07 s/60°. The jump from 8.4 V to 12 V is where the headline figure lives — budget a 3S-capable BEC if you want the 40.
Stall current stays at or under 4.0 A across the range, no-load 320–440 mA. A 5 A BEC will run one of these with margin; two on the same BEC at stall is 8 A and that is where receivers start resetting.
FAQ
Why is it called a tail servo with a standard pulse window?
The inspection sheet uses the tail-servo name and the 8H series code, but the printed control window is the standard 800–2200 µs. Unlike the narrow-window tail servos in this range, it accepts a normal channel — check the sheet, do not assume from the name.
Why 1520 µs neutral instead of 1500?
That is what the inspection sheet states — a 20 µs offset from the usual centre. Set the sub-trim once on the bench; do not leave it to the gyro’s default.
Does the RS-485 build speak Modbus?
The inspection sheet lists RS-485 as the command signal and nothing more. Ask for the register map and the supported function codes before you write the controller code — do not assume a Modbus dialect.
How many servos can share the bus?
The limit is the address space and the current budget of the shared supply. Terminate the pair at both ends and keep the power pair separate from the signal pair.
Other interfaces
Downloads
- XQ-RS8140H inspection specification (PDF, 891 KB)
Torque, speed and current at each supply voltage, mechanical data, control specification, mounting dimensions. - 2D dimension drawing (image)
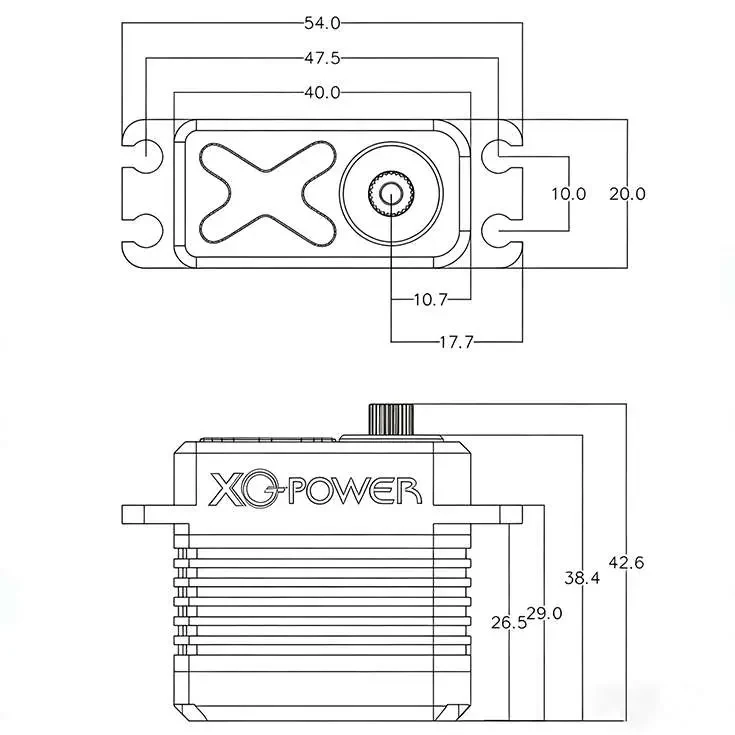
Mounting hole positions, case depth and overall height; the same drawing is inside the datasheet.