| 130KG·CM STALL | 0.140S/60° NO-LOAD | 16.8V RATED |
| 411G WEIGHT | SteelGEARTRAIN | 360°TRAVELCustomizable |
Overview
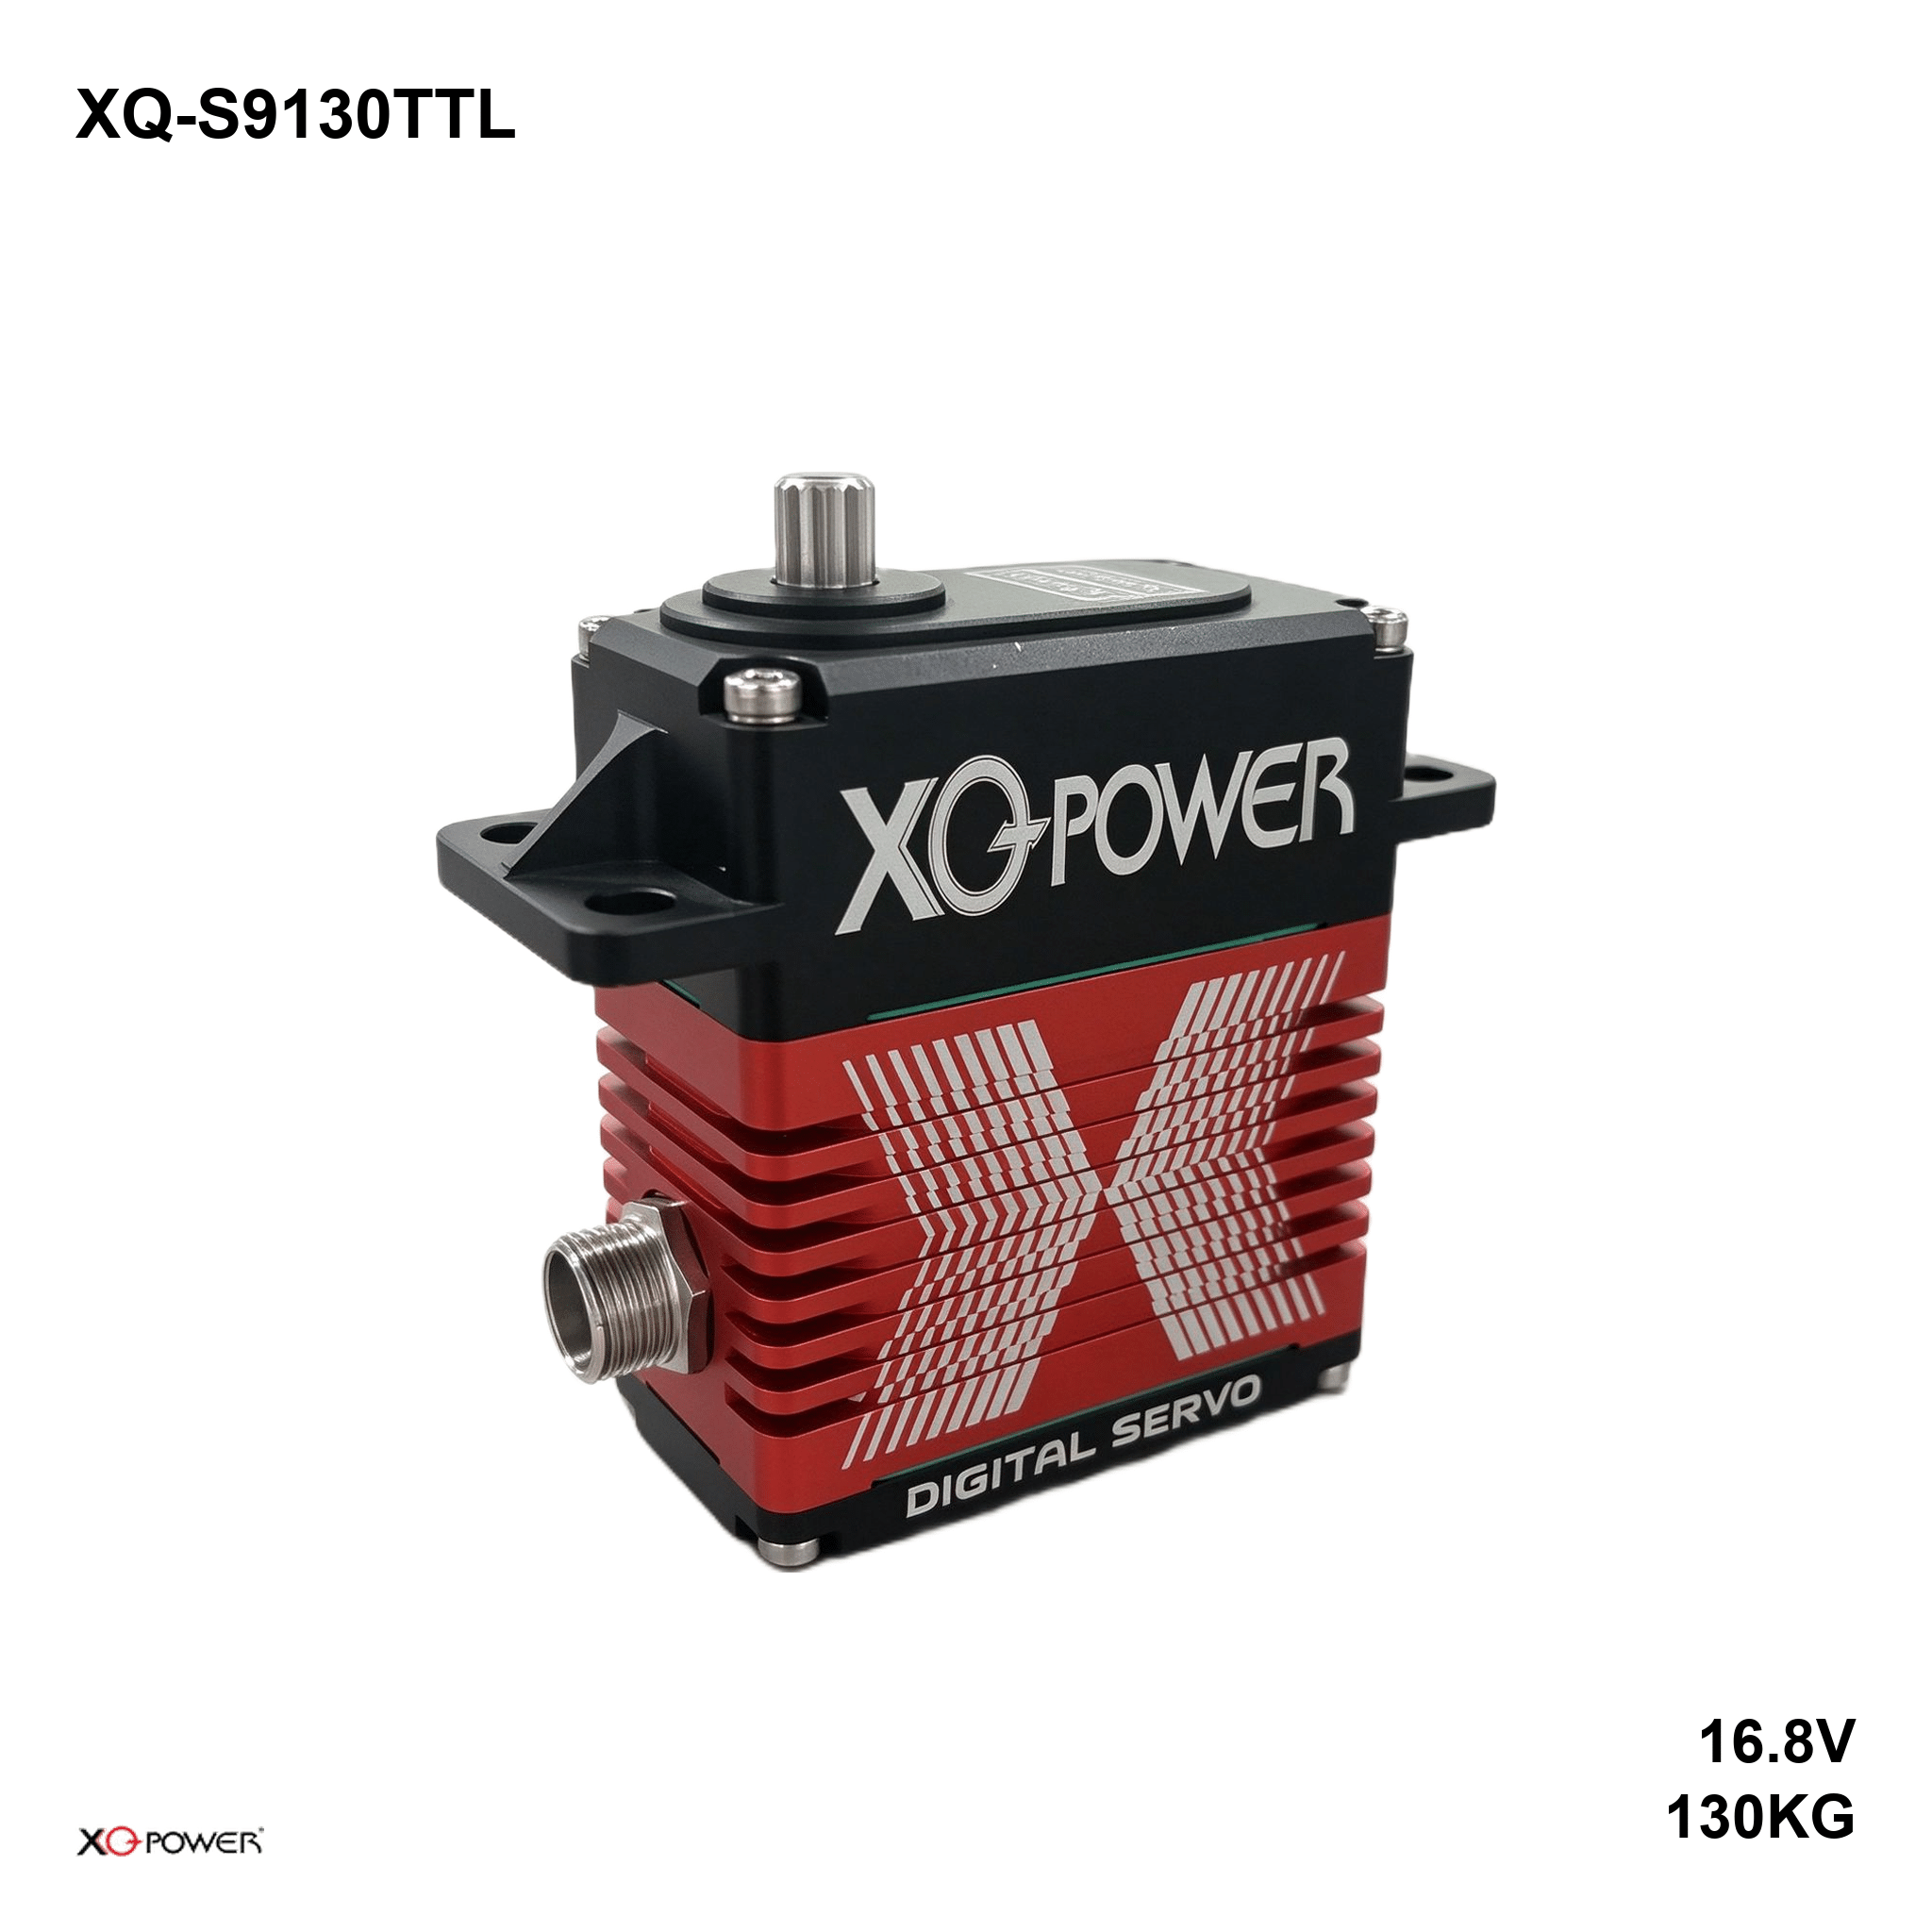
The 9130 is the tall-case 130 kg·cm brushless servo: 64 × 33 × 76 mm, 411 g, 7075 aluminium CNC body with a red anodised fin stack, and a 220° mechanical limit on the output.
The geartrain is steel on two ball bearings, the output is a 25T-φ9.95 mm spline with a metal horn, and the servo ships with a 500 mm lead. Ratings are 100, 115 and 130 kg·cm at 8.4, 12.6 and 16.8 V, with stall current at or under 9 A.
This page covers the TTL build: the same mechanics, commanded over a serial bus so several servos can share one signal line and be addressed individually. Useful when the actuator count outgrows the PWM channels available.
Performance at each supply voltage
| Supply | No-load speed | Peak stall torque | Idle current | Stall current |
|---|---|---|---|---|
| 8.4 V | 0.280 s/60° (214 °/s) | 100 kg·cm (9.81 N·m / 1389 oz·in) | 150 mA | 6.5 A |
| 12.6 V | 0.170 s/60° (353 °/s) | 115 kg·cm (11.28 N·m / 1597 oz·in) | 270 mA | 8 A |
| 16.8 V | 0.140 s/60° (429 °/s) | 130 kg·cm (12.75 N·m / 1805 oz·in) | 400 mA | 9 A |
Control specification
| Item | Specification |
|---|---|
| Command signal | TTL serial |
| Amplifier | Digital controller |
| Dead band | 4 µs |
| Rotating direction | CCW (1000–2000 µs), customizable |
| Travel | 360°, customizable |
Mechanical specification
| Item | Specification | Item | Specification |
|---|---|---|---|
| Dimensions | 64 × 33 × 76 mm | Case material | 7075 aluminium, CNC |
| Weight | 411 g | Geartrain | Steel |
| Bearings | 2 × ball bearing | Motor | Brushless |
| Output spline | 25T-φ9.95 mm | Horn | Metal |
| Lead / connector | 500 mm | Mechanical limit | 220° |
| Operating temperature | −20 °C to 60 °C | Storage temperature | −30 °C to 70 °C |
| Ingress protection | Splash resistant (customizable) | Travel | 360°, customizable |
What’s in the box
- 1 × XQ-S9130TTL servo
- 1 × 7075 aluminium horn
- 1 × mounting screw pack
How to size it
At 8.4 V it is a 100 kg·cm servo at 0.28 s/60°; to get the 130 kg·cm headline you need 16.8 V, where the no-load speed is 0.14 s/60°. Size the linkage at the rail you will actually run, and remember the case weight — 411 g at the end of a lever arm is inertia the servo has to drive.
Stall current reaches 9 A at 16.8 V. For a long holding application, the average current matters more than the stall number: budget the supply for the holding torque you need, and the fins will handle the rest.
FAQ
How is it different from the 9100?
Same 130 kg·cm class, different mechanics: the 9130 is 64 × 33 × 76 mm and 411 g with a 7075 case and a 220° mechanical limit, the 9100 is 61 × 30 × 61.4 mm and 190 g with no limit.
Is the 220° limit a hard stop?
Yes, mechanically. The running degree is 360° on a customized build, so state the travel you need when ordering rather than expecting the standard unit to rotate past its limit.
Is the pulse width table valid for this unit?
No. The microsecond window printed on the inspection sheet belongs to the PWM build of the same servo. This unit is commanded over the serial bus — ask for the command set and register map before writing firmware.
How many can share one bus?
The limit is the address space and the current budget of the shared supply, not the signal pair. Keep the bus ground common with the power ground at a single point.
Other interfaces
Downloads
- XQ-S9130TTL inspection specification (PDF, 962 KB)
Torque, speed and current at each supply voltage, mechanical data, control specification, mounting dimensions. - 2D dimension drawing (image)
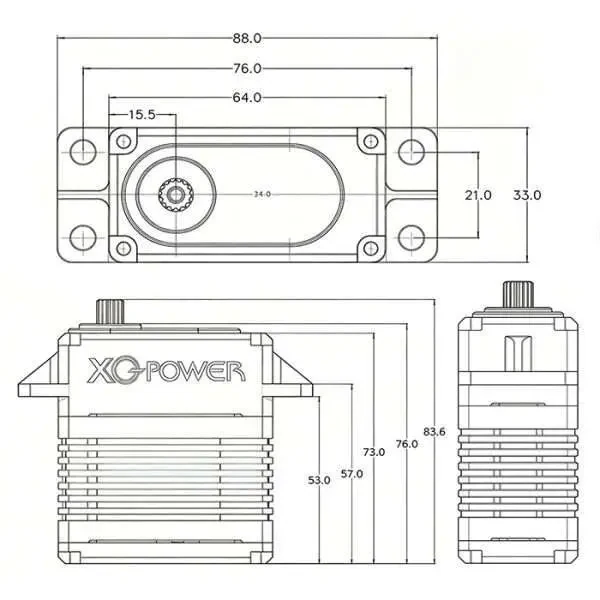
Mounting hole positions, case depth and overall height; the same drawing is inside the datasheet.