| 35KG·CM STALL | 0.100S/60° NO-LOAD | 8.4V RATED |
| 77G WEIGHT | StainlessGEARTRAIN | 360°TRAVELCustomizable |
Overview
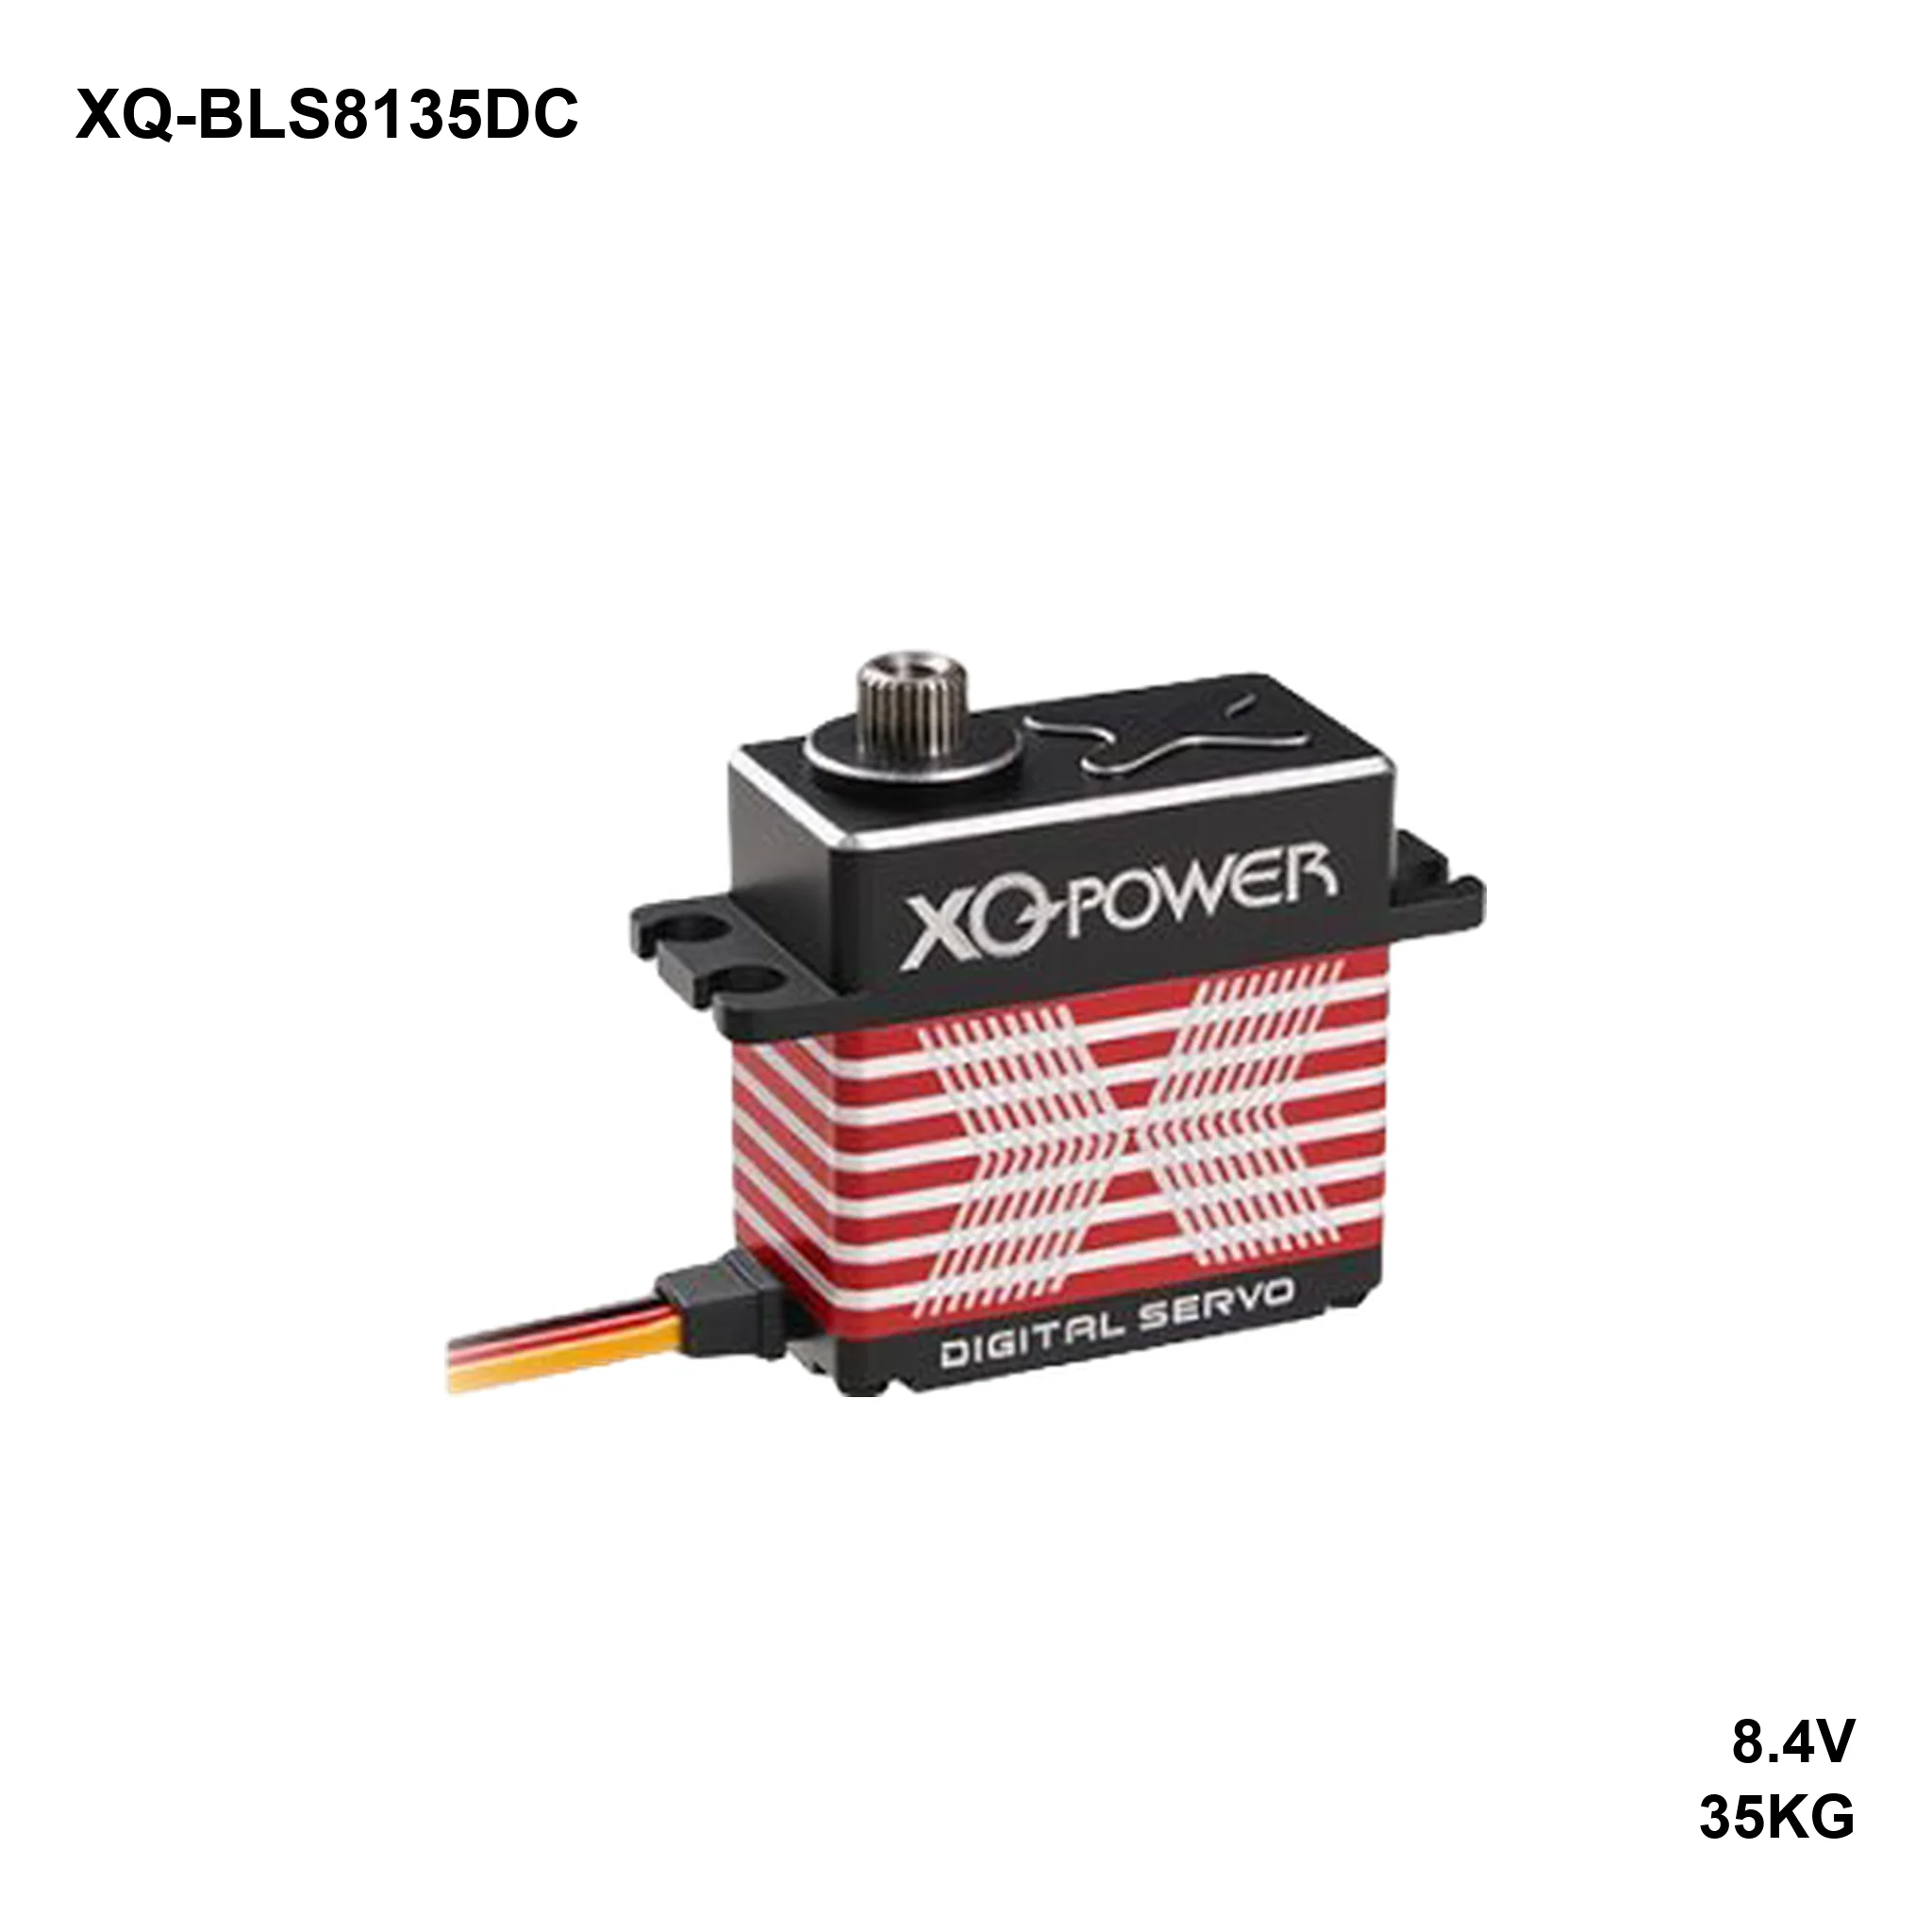
The BLS8135D is the 35 kg·cm brushless servo in the standard 20 × 40 × 38.4 mm case, 77 g. At 8.4 V it swings 0.10 s/60°; drop to a 6.0 V receiver pack and the same servo is 20 kg·cm at 0.14 s.
Stainless steel geartrain on two ball bearings, CNC aluminium case with the fins milled into the sides, 25T-φ5.94 mm output and a POM horn. The mechanical limit is 210°, the dead band 1 µs, and the lead is 300 mm of three-wire cable.
This page covers the CAN build: the same mechanics on a CAN bus, with arbitration and error checking handled in hardware. The version to pick when the machine already speaks CAN and a dropped frame must not become a wrong angle.
Performance at each supply voltage
| Supply | No-load speed | Peak stall torque | Idle current | Stall current |
|---|---|---|---|---|
| 6.0 V | 0.140 s/60° (429 °/s) | 20 kg·cm (1.96 N·m / 278 oz·in) | 320 mA | 2.8 A |
| 7.4 V | 0.120 s/60° (500 °/s) | 28 kg·cm (2.75 N·m / 389 oz·in) | 370 mA | 3.5 A |
| 8.4 V | 0.100 s/60° (600 °/s) | 35 kg·cm (3.43 N·m / 486 oz·in) | 440 mA | 4.0 A |
Control specification
| Item | Specification |
|---|---|
| Command signal | CAN bus |
| Amplifier | Digital controller |
| Dead band | 1 µs |
| Rotating direction | CCW (1000–2000 µs) |
| Travel | 360°, customizable |
Mechanical specification
| Item | Specification | Item | Specification |
|---|---|---|---|
| Dimensions | 20 × 40 × 38.4 mm | Case material | Aluminium, CNC |
| Weight | 77 g | Geartrain | Stainless steel |
| Bearings | 2 × ball bearing | Motor | Brushless |
| Output spline | 25T-φ5.94 mm | Horn | Plastic, POM |
| Lead / connector | 300 mm, 3-wire | Mechanical limit | 210° |
| Operating temperature | −15 °C to 65 °C | Storage temperature | −20 °C to 70 °C |
| Ingress protection | Splash resistant (customizable) | Travel | 360°, customizable |
What’s in the box
- 1 × XQ-BLS8135DC servo
- 1 × POM horn set
- 1 × mounting screw pack
Optional: metal horn, sold separately.
How to size it
Torque tracks the rail: 20 kg·cm at 6.0 V, 28 at 7.4 V, 35 at 8.4 V, at 0.14, 0.12 and 0.10 s/60°. On a 2S pack that sits near 7.4 V under load, plan on 28 kg·cm and treat 35 as the fresh-pack number.
Stall current is 4.0 A. Four of these on one BEC is 16 A at stall — size the BEC for the worst case, or run a separate servo rail. Brownouts on 35 kg·cm class models are almost always a supply problem, not a servo fault.
FAQ
BLS8135D or BLS8145D?
Same case, same 25T spline, same 20 × 40 × 38.4 mm footprint. The 8145D is 73 g and reaches 48 kg·cm at 8.4 V but draws 5.2 A at stall; the 8135D is 77 g, 35 kg·cm and 4.0 A. Pick on torque headroom versus current budget.
What supply voltage?
6.0 to 8.4 V. The headline 35 kg·cm is the 8.4 V figure; at 7.4 V it is 28 kg·cm and at 6.0 V it is 20.
What bitrate and message set does it use?
Not printed on the inspection sheet. Ask for the CAN message set, bitrate options and node ID range before integration; they are supplied on request.
Why CAN instead of RS-485?
Arbitration and error detection are in hardware, so a corrupted frame is discarded rather than acted on, and several nodes can share the bus without a master polling loop.
Other interfaces
Downloads
- XQ-BLS8135DC inspection specification (PDF, 722 KB)
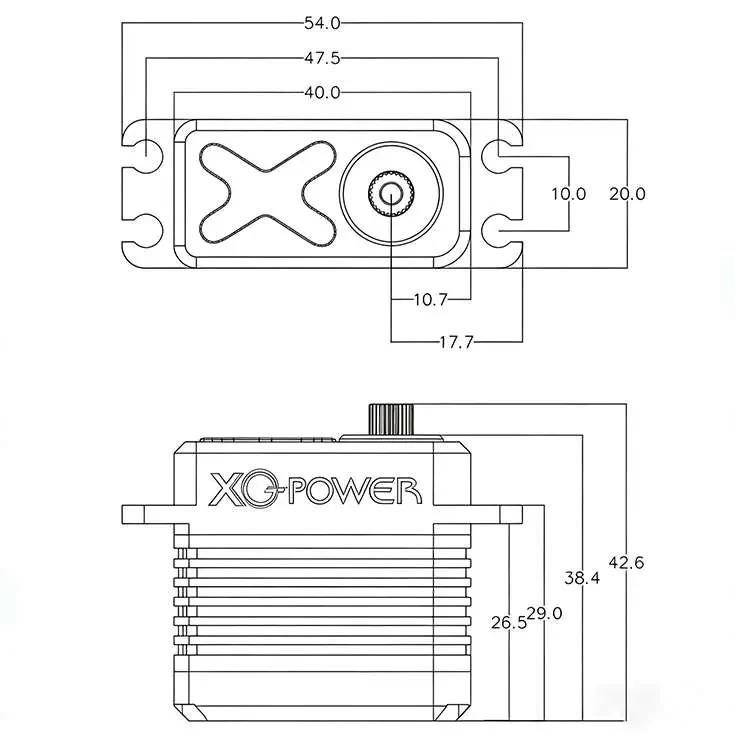
Torque, speed and current at each supply voltage, mechanical data, control specification, mounting dimensions. - 2D dimension drawing (image)
Mounting hole positions, case depth and overall height; the same drawing is inside the datasheet.