Twelve joints, one bus: allocating torque in a quadruped leg
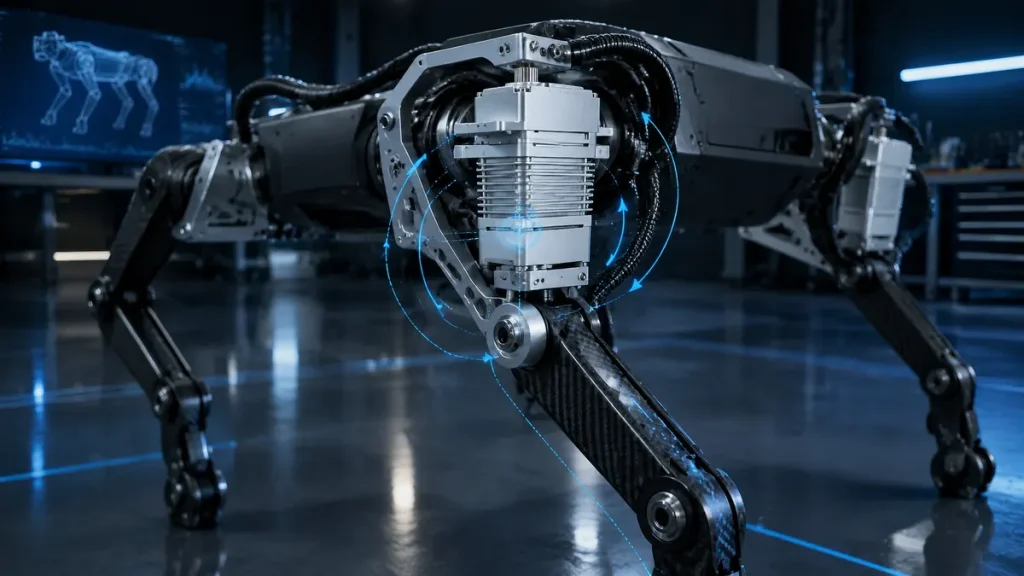
Hip abduction, hip flexion and knee share a load path that changes with every gait phase. How the torque budget is split across the three, and where the margin belongs.
Engineering insights for legged robots, robotic arms, mobile robots and AMR platforms, including actuator selection, drive systems and motion control.
Hip abduction, hip flexion and knee share a load path that changes with every gait phase. How the torque budget is split across the three, and where the margin belongs.