| 40KG·CM STALL | 0.070S/60° NO-LOAD | 12V RATED |
| 78G WEIGHT | StainlessGEARTRAIN | 360°TRAVELCustomizable |
Overview
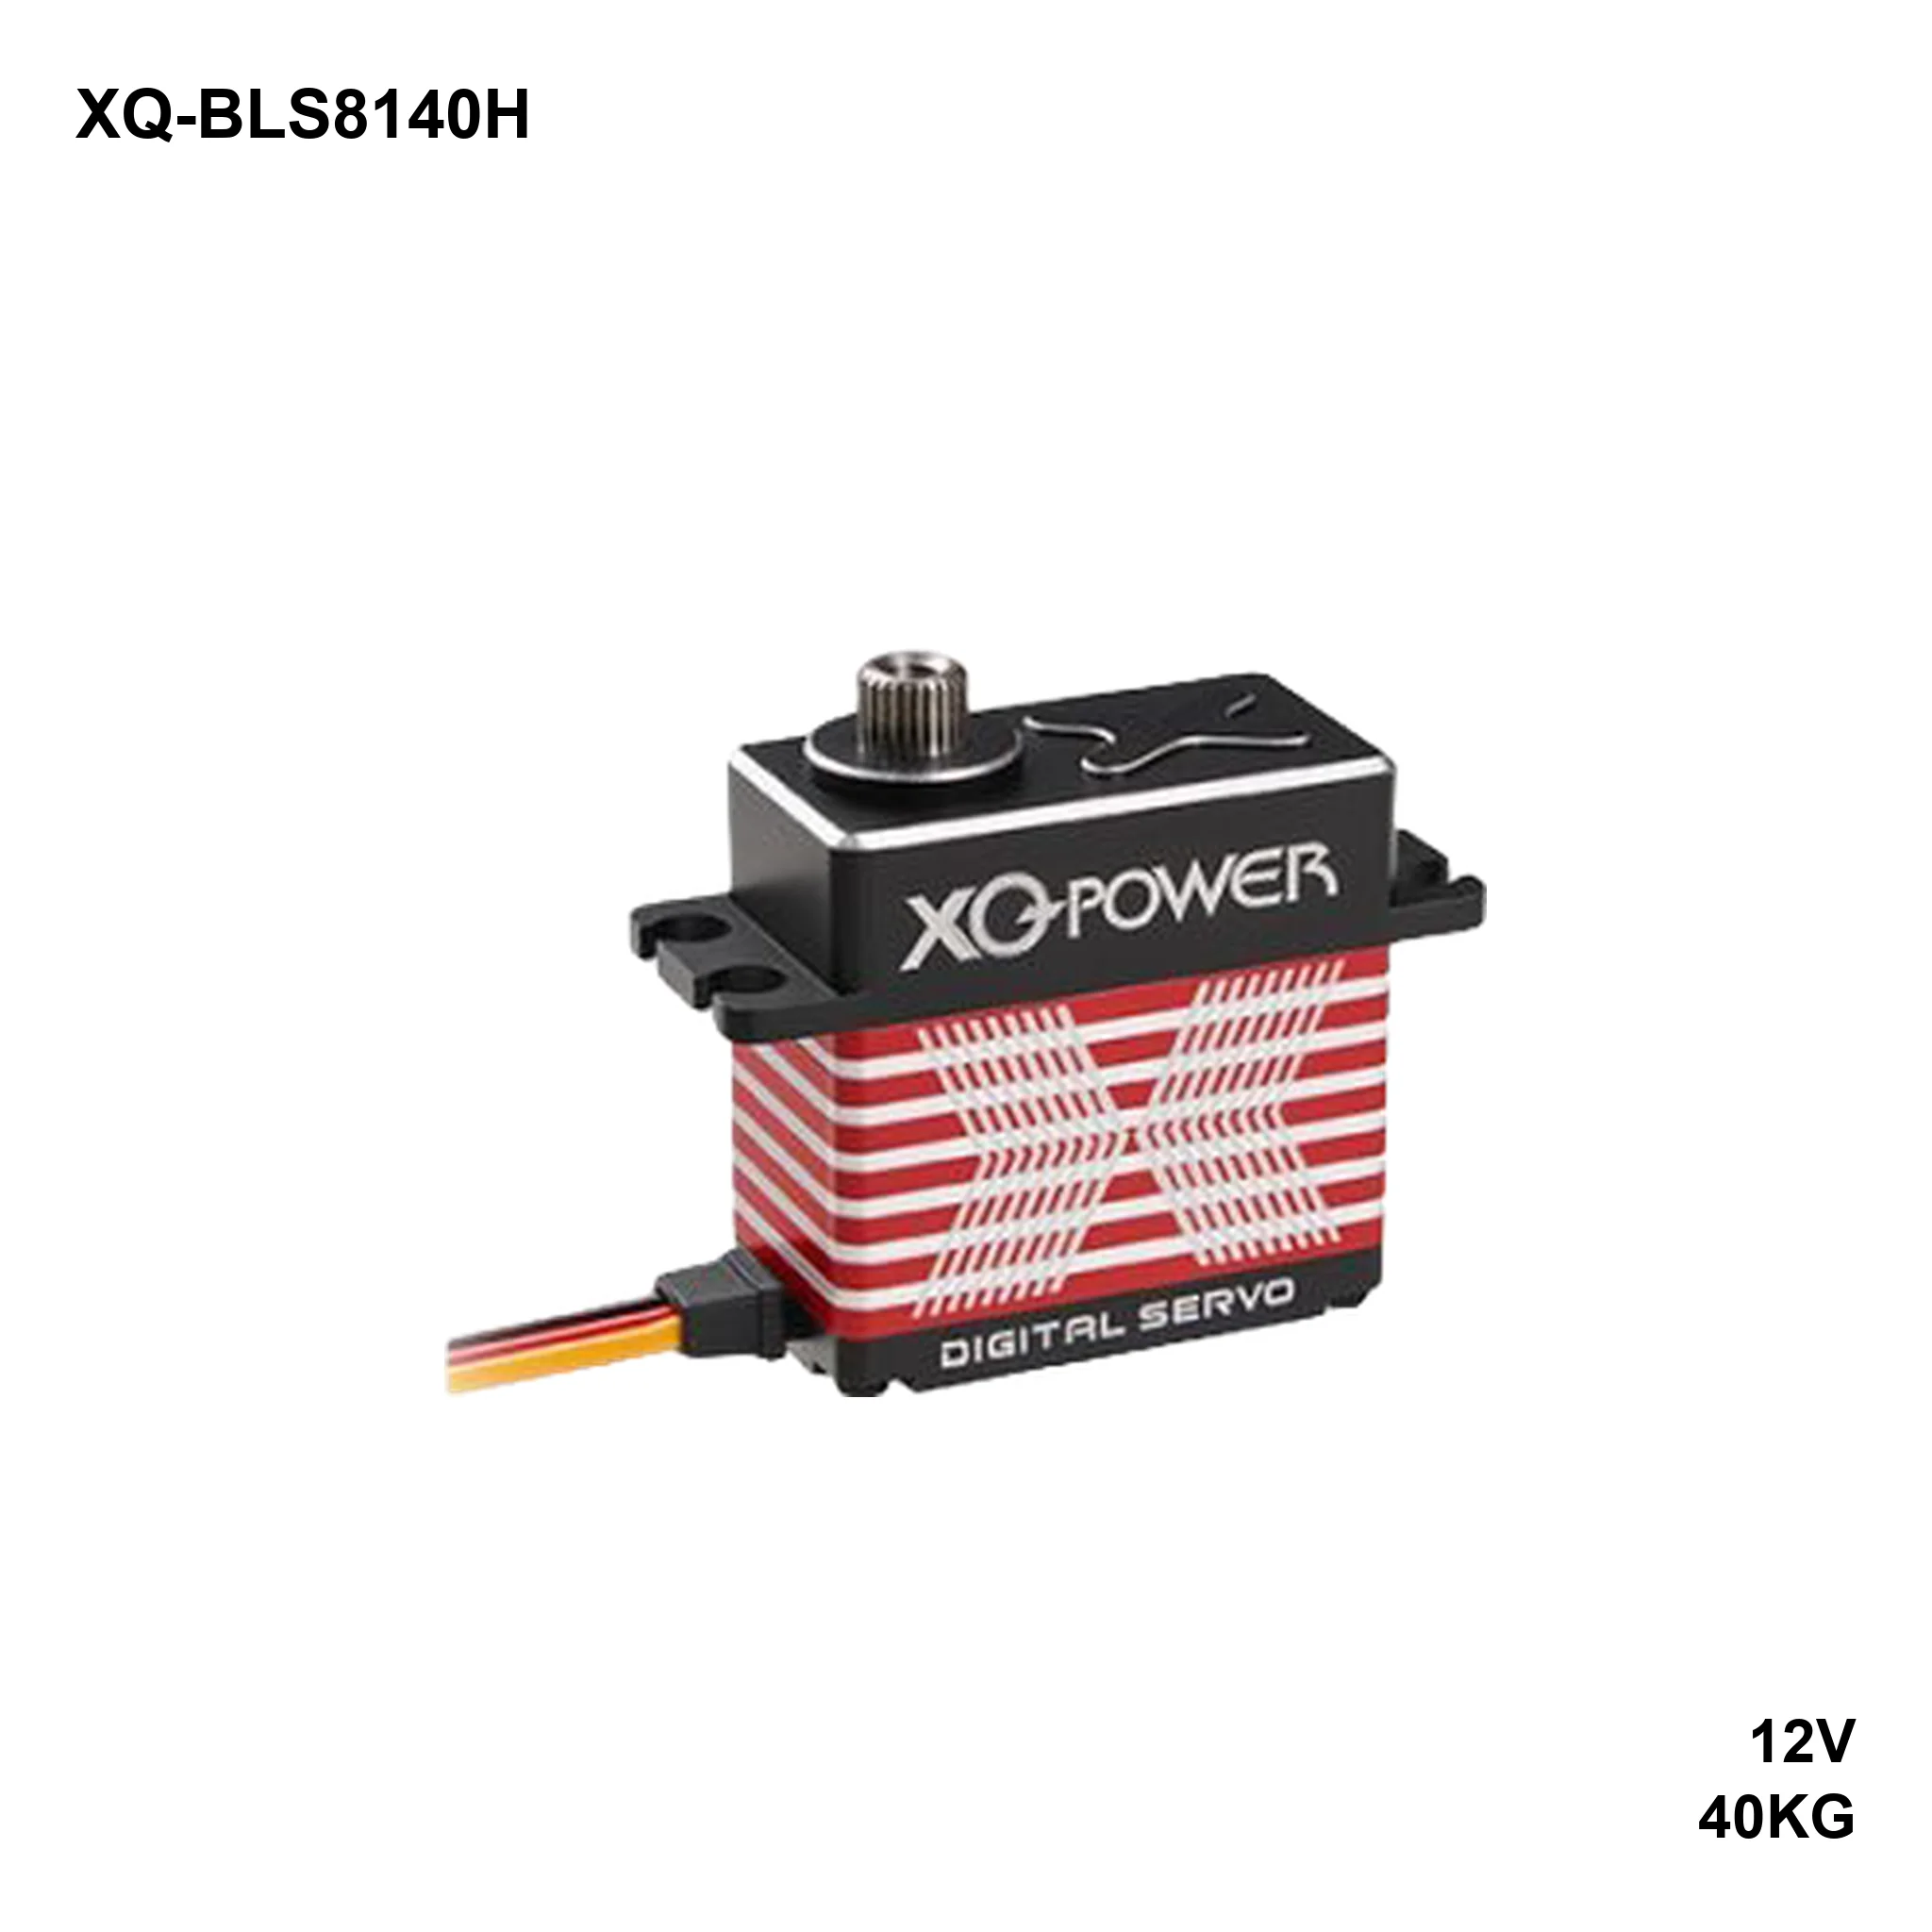
The BLS8140H is the 12 V build of the standard-size brushless servo: 40 kg·cm at 0.07 s/60° on a 3S rail, 78 g in a 20 × 40 × 38 mm aluminium case. On 8.4 V it is a 29 kg·cm servo and on 7.4 V a 25 kg·cm one, so it stays usable across a 2S to 3S swap.
The inspection sheet names it a tail servo and it carries the 8H series code, but the control window is the standard 800–2200 µs with a **1520 µs** neutral — 20 µs off the usual 1500. That offset is small enough to be invisible on a stick and large enough to matter on a gyro that expects a true centre, so trim it out on the bench before the first flight.
This page covers the PWM build: a standard 50–333 Hz pulse input, 1500 µs neutral and a 3–4 µs dead band. It is the version to pick when the servo hangs off a receiver or a flight controller and you want nothing between the two.
Performance at each supply voltage
| Supply | No-load speed | Peak stall torque | Idle current | Stall current |
|---|---|---|---|---|
| 7.4 V | 0.110 s/60° (545 °/s) | 25 kg·cm (2.45 N·m / 347 oz·in) | 320 mA | 2.8 A |
| 8.4 V | 0.094 s/60° (638 °/s) | 29 kg·cm (2.84 N·m / 403 oz·in) | 370 mA | 3.5 A |
| 12 V | 0.070 s/60° (857 °/s) | 40 kg·cm (3.92 N·m / 555 oz·in) | 440 mA | 4.0 A |
Control specification
| Item | Specification |
|---|---|
| Command signal | PWM |
| Amplifier | Digital controller |
| Pulse width range | 800–2200 µs |
| Neutral position | 1520 µs |
| Dead band | 1 µs |
| Rotating direction | CCW (1000–2000 µs) |
| Travel | 360°, customizable |
Mechanical specification
| Item | Specification | Item | Specification |
|---|---|---|---|
| Dimensions | 20 × 40 × 38 mm | Case material | Aluminium, CNC |
| Weight | 78 g | Geartrain | Stainless steel |
| Bearings | 2 × ball bearing | Motor | Brushless |
| Output spline | 25T-φ5.96 mm | Horn | Plastic, POM |
| Lead / connector | 300 mm, 22 AWG | Mechanical limit | 210° |
| Operating temperature | −15 °C to 65 °C | Storage temperature | −20 °C to 70 °C |
| Ingress protection | Splash resistant (customizable) | Travel | 360°, customizable |
What’s in the box
- 1 × XQ-BLS8140H servo
- 1 × POM horn set
- 1 × mounting screw pack
Optional: metal horn, sold separately.
How to size it
Torque is 25 kg·cm at 7.4 V, 29 at 8.4 V and 40 at 12 V, at 0.11, 0.094 and 0.07 s/60°. The jump from 8.4 V to 12 V is where the headline figure lives — budget a 3S-capable BEC if you want the 40.
Stall current stays at or under 4.0 A across the range, no-load 320–440 mA. A 5 A BEC will run one of these with margin; two on the same BEC at stall is 8 A and that is where receivers start resetting.
FAQ
Why is it called a tail servo with a standard pulse window?
The inspection sheet uses the tail-servo name and the 8H series code, but the printed control window is the standard 800–2200 µs. Unlike the narrow-window tail servos in this range, it accepts a normal channel — check the sheet, do not assume from the name.
Why 1520 µs neutral instead of 1500?
That is what the inspection sheet states — a 20 µs offset from the usual centre. Set the sub-trim once on the bench; do not leave it to the gyro’s default.
What pulse range does it accept?
The inspection sheet specifies a 500–2500 µs window (800–2200 µs on the 9130/9150) with 1500 µs neutral, both customizable at order. Feeding it outside that window is out of spec.
Can I drive it from a normal receiver?
Signal-wise yes, but check the supply. This servo wants 8.4–16.8 V, not a 6 V receiver pack, so the power rail has to be separate from the receiver’s.
Other interfaces
Downloads
- XQ-BLS8140H inspection specification (PDF, 892 KB)
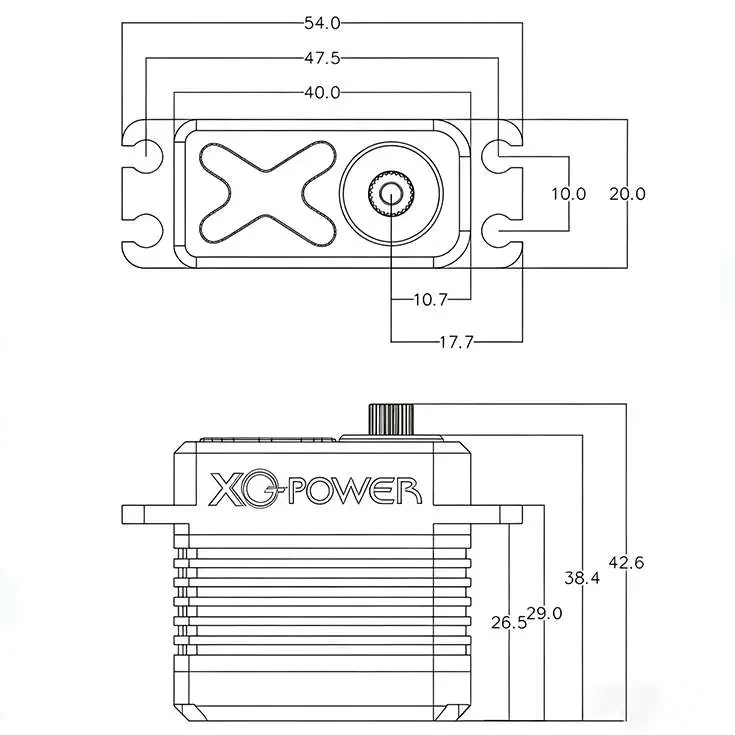
Torque, speed and current at each supply voltage, mechanical data, control specification, mounting dimensions. - 2D dimension drawing (image)
Mounting hole positions, case depth and overall height; the same drawing is inside the datasheet.